Product Description of SP Series Robot Joint Actuators
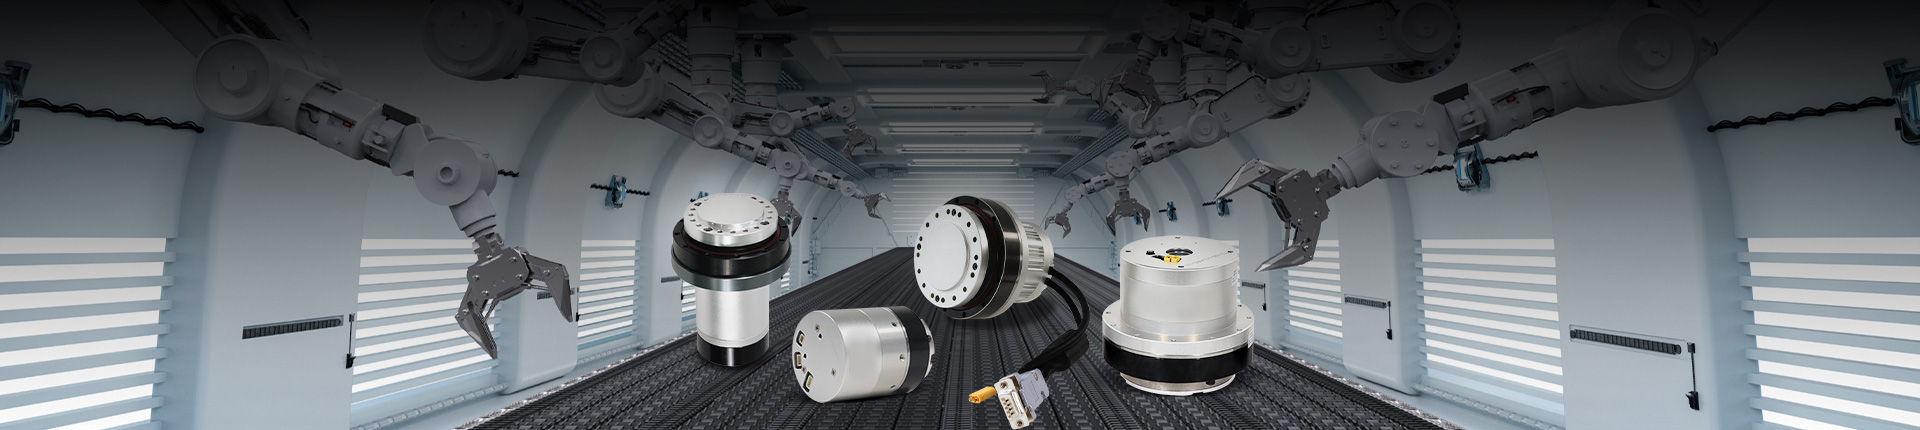
SP(Servo-Planetary) series planetary robot joint module is an integrated Servo joint actuators developed and produced by Avatar Robotics. SP planetary robot joint module is a highly integrated micro-servo joint with precision planetary reducer, torque motor and professional servo drive, which forming a drive control integration. The planetary joints are connected in series through the CAN bus, the wiring is simple and easy to operate, and the failure rate of the whole robot joints is low; The planetary has small size and large torque, especially suitable for bionic robot, bionic animal, educational robot arm and other multi-joint combination application scenarios; At the same time, the integrated planetary Servo joint actuators can replace a variety of brushless motors and large torque steering gear because of its high cost performance and stable performance

CAN 2.0 Protocol
OD 32~52mm MINI PLANETARY INTEGRATED SERVO ACTUATORS
1.0~144Nm rated torque
24V DC voltage
35~72W Power


SP series planetary robot joint actuators are extremely lightweight and compact size.The smallest one is only 180g, the planetary joint motors greatly reduce the operation energy consumption.
| Model |
SP05 |
SP08 |
SP08D |
SP11 |
SP11D |
SP11L |
| Diameter |
32mm |
40mm |
40mm |
52mm |
52mm |
52mm |
| Length |
33.4mm |
52mm |
48mm |
64mm |
61mm |
82mm |
| Weight |
180g |
180g |
200g |
388g |
428g |
494g |
| Reduction Ratio |
6:1 |
36:1 |
| Working Voltage |
24V |
| Max Power |
35W |
36W |
60W |
72W |
| Rated Speed |
50RPM |
| Rated Torque |
0.2NM |
1.0NM |
6.6NM |
12NM |
| Peak Torque |
0.48NM |
2.2NM |
14NM |
18NM |
Product Advantages
High precision metal planetary reducer
-Metal gear, withstand large torque and high precision,
-Backlash difference better than +-12arcmin(0.2 degrees)
-Low noise, high speed <70db
-Low speed and silent
-Output double bearing structure, no axial backlash
High density torque motor
-High density brushless external rotor torque motor
-Low slot torque
-Ultra-long life, normal working time exceeds 5000 hours
Double absolute encoder
-Double absolute encoder 16bit*2
-Single turn absolute encoder in the output end
- Power failure angle is not lost, no external battery is required
Integrated drive, bus control
Driven by FPGA design, stable performance, strong anti-interference
CAN2.0A bus interface, bus rate 1.0MHZ
Supports 254 joints or I/O devices in series
Simple connection, two serial bus one in and one out
Complete parameter setting
-Integrated algorithm, internal integrated track profile working mode,
acceleration and deceleration, speed limit, torque limit, temperature limit can be set
- Current ring frequency 20khz, speed ring 10kHz, position ring 1kHz, the three ring parameters are all open, and various working modes are freely realized.
UBUNTU and WINDOWS upper computer
-Provide UBUNTU and WINDOWS versions of the host computer, easy for users to quickly verify.
-At the same time, C/C++ API can be integrated with LINUX-(ROS)\WINDOWS system to achieve rapid mass production of products
HUMANOID ROBOT-PLANETARY JIONTS
SP05
Wrist joint
Expression joint
SP11
Shoulder joint
Thigh joint
SP08D
Elbow joint
Neck joint
Ankle joint
SP11D
Shoulder joint
Thigh joint
Knee joint
Integrated servo planetary robot joint actuators adopts serial bus connection, which greatly simplifies the system routing, while the joint size is small, the energy density is large, and supports flexible position control and force feedback, which is an excellent solution for simulating robots and bionic animals. Avatar can provide whole-body joint servo motors for artificial robots, with stable performance and low cost. The planetary robot joint actuators has achieved large-scale mass production and established cooperation with a large number of simulation robot companies at home and abroad.
Application

Collaborative Manipulator

Smart manufacturing

Medical Equipment

Exoskeleton
Installation and connection

The upper computer is connected to the joint, and the USB to CAN module needs CAN-able to connect.

Connect cables to the CAN debugger. Connect L to CAN_L, H to CAN_H, G not connect, and R dip switch 1,Dial to ON, and then connect the debugger to the joint.

24V power supply port, plug-in terminal model: XT30UPB-M, distribution terminal model:XT30U-F; 24V connects to the positive terminal of the power supply, GND connects to the negative terminal of the power supply

Communication connection between joint module and upper computer: connect with UCB_CAN connection board, connect USB turn CAN device (Canable_CandleLight) to the USB port of the computer, connect the integrated motor joint to USB ,turn CAN device on and power on.
⚠️ Note: Specifications are subject to updates. Please confirm the latest specifications with our product manager before
placing an order.
| Model |
SP05 |
SP08 |
SP08D |
SP11 |
SP11D |
SP11L |
| Motor Type |
Brushless torque motor |
| Reducer Type |
Planetary reducer |
| Diameter |
32mm |
40mm |
40mm |
52mm |
52mm |
52mm |
| Length |
33.4mm |
52mm |
48mm |
64mm |
61mm |
82mm |
| Weight |
180g |
180g |
200g |
388g |
428g |
494g |
| Reduction Ratio |
6:1 |
36:1 |
| Reverse Backlash |
12arcmin |
| Noise |
<70db |
| Temperature Range |
-20~80℃ |
| Working Voltage |
24V |
| Max Power |
35W |
36W |
60W |
72W |
| Rated Speed |
50RPM |
| Rated Torque |
0.2NM |
1.0NM |
6.6NM |
12NM |
| Peak Torque |
0.48NM |
2.2NM |
14NM |
18NM |
| Phase Current Full Scale |
|
4.0A |
14A |
20A |
| Maximum Busbar Current |
|
1.5A |
5A |
2A |
| Static Busbar Current |
|
0.04A |
| Torque Coefficient |
1.1NM/A |
1.1NM/A |
2.2NM/A |
6NM/A |
| Radial Force |
|
2520N |
3150N |
| Axial Force |
|
1284N |
1605N |